Sunday, March 8, 2015

Arduino Due - USB keyboard with PSK31 encoder

Updated: I have updated the code below to fix a compiler warning error.  The code below also requires the USBHost library be installed.  See the comments at the end of the posting to get the details of how to do this if you have any questions.

I have spent a few minutes today building an example PSK31 keyboard based on the Arduino Due and the recent work I posted to generate PSK31 from an Arduino Uno or Mega2560.

Firstly, I will discuss the necessary changes to implement my PSK31 encoder on the Due and then the changes needed to incorporate a USB keyboard as the beginnings of a full-function PSK31 encoder.

Readers of my previous blog posts on Generating PSK31 with an Arduino (a total of 4 posts, the other three of which are linked with the referenced article) will know that I generate PSK31 tones using a timer interrupt to construct the audio waveform from (un-optimized) memory tables of sinusoidal information.  If interested, you should also check out the recent excellent work by Jim Harvey (WB8NBS) to optimize the size of memory-resident sinusoidal data from my previous work on software DDS on the Arduino.

Generating timer interrupts on the Due is quite flexible and I have previously posted an extensive article on the topic of using Timer Counters on the Due.  Please have a look for all the gory details.

In porting my PSK31 Arduino code over to the Due, the main change that was necessary was surrounding how timers work.

// Set up Timer/Counter (TC)
void TimerStart(Tc *tc, uint32_t channel, IRQn_Type irq, uint32_t freq)
{
   pmc_set_writeprotect(false);
   pmc_enable_periph_clk(irq);
   TC_Configure(tc, channel, TC_CMR_WAVE | TC_CMR_WAVSEL_UP_RC |
                             TC_CMR_TCCLKS_TIMER_CLOCK1);
   uint32_t rc = VARIANT_MCK / 2 / freq;
   TC_SetRC(tc, channel, rc);
   TC_Start(tc, channel);
   tc->TC_CHANNEL[channel].TC_IER=  TC_IER_CPCS; // | TC_IER_CPAS;
   tc->TC_CHANNEL[channel].TC_IDR=~(TC_IER_CPCS); // | TC_IER_CPAS);
   NVIC_EnableIRQ(irq);

}

My previous article on Timers on the Due uses a variant of this function to set up a timer to interrupt at an appropriate rate to generate all phase points of a sinusoid at the desired freqency.

The only change here is to use a different timer clock.  In this case I chose to use TIMER_CLOCK1 which is the master clock (84 MHz) divided by 2.  We divide this by the desired frequency of 31.25 kHz and set a counter match interrupt at this value.  The counter will now count (at 42 MHz) up to 1344 and fire an interrupt, effectively dividing 42 MHz down to 31.250 kHz.

The timer handler as described in my article on Due timers is called TC3_Handler because we are using Timer/Counter 1 channel 0.  Please see the table in my previous article for the mapping of Timer/Counter channels to handler function names.

// Grab the next phase point from the table and 
// set the amplitude value of the sinusoid being
// constructed.  For a one bit, set 500 phase points
// (20 amplitudes of 25 samples each) to ramp
// down to zero and then immediately back up to full
// amplitude for a total of 1024 phase points.
//
// For a zero bit, there is not amplitude or phase
// change, so we just play 20 phase points of
// full amplitude data 25 times for a total of 1000
// phase points.
//
// Each end of the ramp-up table starts with a zero 
// crossing byte, so there is one extra byte in
// the table (501 entries).  Ramping up plays bytes
// 0 -> 499 and ramping down plays bytes 500 -> 1
// allowing each direction to start at the zero
// crossing point.

//TC1 ch 0
void TC3_Handler()
{
   TC_GetStatus(TC1, 0);  // Reset TC
   
  // Set current amplitude value for the sine wave 
  // being constructed taking care to invert the
  // phase when processing the table in reverse order.
  analogWrite(DAC0, (*pbSine * ix * phase) & 0xff);
  pbSine += ix;
  
  // At the half bit time, we need to change phase
  // if generating a zero bit
  if (0 == --cbHalfBit)
  {
    cbHalfBit = 500;  // Reset 1/2 PSK bit time phase counter
    
    // Get the next varichar bit to send
    if (fFullBit)
    {
      // Count the number of sequential zero bits
      if (fSendOne = vcChar & 1) cZeroBits = 0; else cZeroBits++;

      // Shift off the most least significant bit.
      vcChar >>= 1;
      
      // If we have sent two zero bits, end of character has occurred
      if (cZeroBits > maxZeroBits)
      {
        cZeroBits = 0;
        
        // If send buffer not empty, get next varicode character
        if (head != tail)
        {
          // Assumes a 256 byte buffer as index increments modulo 256
          vcChar = varicode[rgchBuf[head++]];
        }
        else
          if (maxZeroBits > 2) stopTX(); else maxZeroBits = 4;
      }
    }
    fFullBit = !fFullBit;  // Toggle end of full bit flag
    
    // When we get done ramping down, phase needs to
    // change unless we are sending a one bit
    if (ix < 0 &&!fSendOne) phase = -phase;
  }
  
  // At the end of the table for the bit being
  // generated, we need to change direction
  // and process the table in the other direction.
  if (0 == --cbDirection)
  {
    cbDirection = fSendOne ? 20 : 500;
    ix = -ix;
  }

}

I added two functions to start and stop the PSK engine as appropriate.

// True if the PSK engine is currently sending data
uint8_t fIsSending = false;

// Start the PSK engine transmitting if it is not already
void startTX()
{
  if (fIsSending) return;
    
  // Set timer to 31.25 kHz for a period of 32 us and start it
  TimerStart(TC1, 0, TC3_IRQn, 31250);
  fIsSending = true;
}

// Stop the PSK engine transmitting
void stopTX()
{
  TC_Stop(TC1, 0);
  fIsSending = false;

}

I also put the DAC into 8 bit mode to be compatible with my sinusoidal tables, though 12 bit mode could be easily accomodated.


  // Use 8 bits in analogue conversions
  analogWriteResolution(8);
  analogReadResolution(8);

So, the remaining details are in the integration of a USB keyboard to the Due.  Fortunately, the out-of-box experience with the Due supports USB host directly, so there was precious little for me to do here.


// Include the keyboard controller library to add USB keyboard support

#include <KeyboardController.h>

// Initialize the USB controller
USBHost usb;

// Attach keyboard controller to USB

KeyboardController keyboard(usb);

I then, added some example keyboard support functions to detect when a key is pressed and to enable some simple example keyboard macros.

// Keyboard functionality follows
// Intercept key release
void keyReleased()
{
  char rgchTemp[] = {0, 0};
  const char *szText = &rgchTemp[0];
  int  cchText = 0;
  
  switch (keyboard.getOemKey())
  {
    case 58:  // F1
      szText = "\nCQ CQ CQ de ko7m ko7m ko7m"
               "\nCQ CQ CQ de ko7m ko7m ko7m"
               "\nCQ CQ CQ de ko7m ko7m ko7m CN87xp pse k\n";
      break;
      
    case 59:  // F2
      szText = "\n Me: Jeff - ko7m"
               "\nLoc: Redmond, Washington USA"
               "\nGrd: CN87xp"
               "\nQSL: eQSL, direct or bureau"
               "\nRig: Homebrew SSB transceiver"
               "\nAnt: G5RV at about 8 metres"
               "\nPSK: Homebrew Arduino Due software"
               "\n";
      break;

    case 60:  // F3
      szText = "\n\nSo, back to you!\n";
      break;
      
    case 61:  // F4
      szText = "\nTnx for the nice QSO"
               "\nBest of 73's to you and yours!"
               "\n";
      break;
      
    case 62:  // F5
      szText = " de jeff -ko7m\n\n";
      break;
    
    case 40:  // CR
      szText = "\r\n";
      break;
      
    default:
      rgchTemp[0] = keyboard.getKey();
      rgchTemp[1] = 0;
      break;
  }
  
  cchText = strlen(szText);
  while (cchText--)
    rgchBuf[tail++] = *szText++;

  startTX();  // Start the PSK engine if it is stopped

}

That is about it!  A couple of things are left to the reader to provide as desired.  I have not created a complete turn-key solution, but rather have provided the main building blocks for you to base a complete solution of your own design on as desired.

  • You get to type blind.  There is no display currently on my Due, nor am I using the serial terminal in order to provide feedback as to what you are typing.  This could be done with a local LCD display, the serial monitor screen or a separate display connected to the second USB port or connected to any of the serial ports.
  • You must provide the necessary DAC buffer electronics in order to not load the DAC pin of your Due as it will not source much current before the output FET blows up.  I am using a simple LM386-based powered computer speaker with a DC blocking capacitor in series with a current limiting resistor.

    IMPORTANT: You will blow the output FET on your Due if you hook low impedance speakers or headphones directly to the DAC pin - don't do it.


The Due outputs a true analogue signal, so no external integrator is required.  I bring the audio out directly from the DAC0 pin to the buffering circuitry (yellow wire).  Brown wire is the ground connection.


The keyboard connects to the Due on the "Native USB Port" (right hand USB connector, furthest from the power connector) and the PC connects to the programming port (left hand USB connector, nearest the power connector).


Normally, you would use a USB OTG (USB on-the-go) cable to connect a keyboard to the Due.

However, since my cable has this nice right-angle connector on the micro-USB end of the cable, it prevented me from using it on the Due when the programming cable is plugged in.  So I instead used a standard USB to micro-USB cable with a female-to-female adapter between that cable and the keyboard cable.
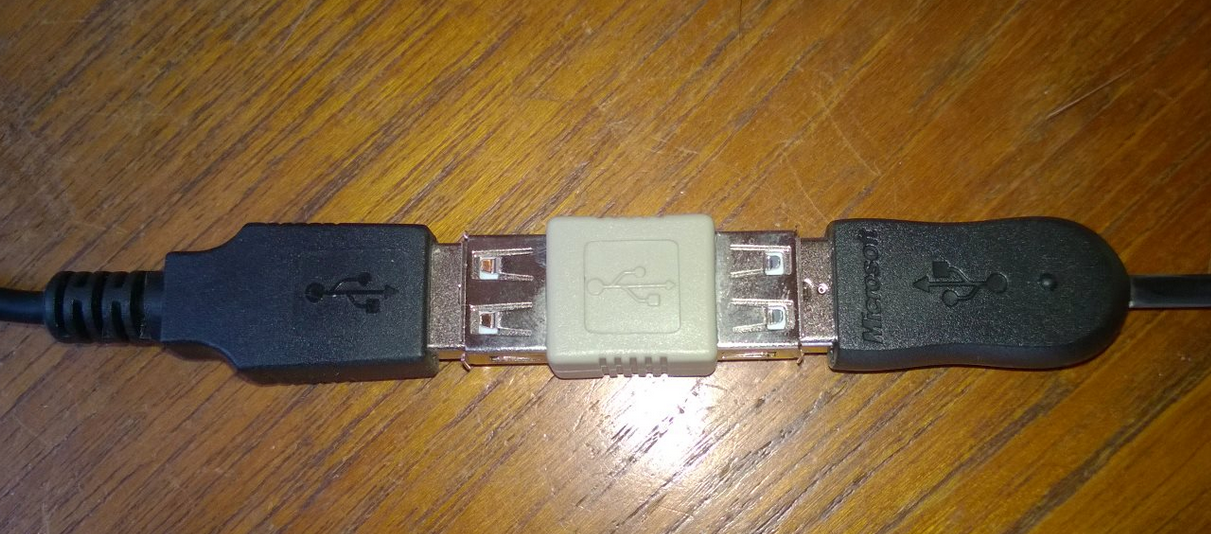

PS2 keyboards could be easily implemented on the Arduino UNO and Mega2560.  Some reference information can be found here.  Any USB host functionality required to support HID devices such as a USB keyboard would be a rather large effort to implement.  PS2 support is much simpler and would be a good option for non-Due Arduino boards.

There is a small start-up delay (of a couple seconds) on the USB host functionality, so if you power on the Due and start typing immediately, there may be some keystrokes that are lost.  I have not investigated yet why this occurs in the standard USB library.

Have fun with this and let me know if you adapt any of this to your purposes.  I have included the complete listing of my code below for your reference.

As always, if you encounter problems or questions, I am happy to try and help.  Drop me a note by replying here or by email at ko7m at arrl dot net.

// PSK31 audio generation - Arduino Due version
// Jeff Whitlatch - ko7m

// Include the keyboard controller library to add USB keyboard support
#include <KeyboardController.h>

// We are going to generate a 1 kHz centre frequency tone.  
// Each 1 kHz cycle of the sinusoid will be generated from
// 32 eight bit amplitude samples.  The period of a 1 kHz tone
// is 1 ms.  Each of the 32 samples per cycle has a period
// of 31.25 us.  We will construct each sinusoid from a 32 byte
// per cycle lookup table of amplitude values ranging from
// 0x00 to 0xff where the zero crossing value is 0x80.

// The PSK31 character bit time is 31.25 ms constructed of 1024
// samples.  A binary zero is represented by a phase reversal
// while a binary 1 is represented by the lack of a phase reversal.

// Characters are encoded with a variable bit length code (varicode)
// where the length of each character is inversely
// proportional to the frequency of use in the english language 
// of that character.  Characters are encoded with a bit
// pattern where there are no sequential zero bits.  Two zero bits
// in a row signify the end of a character.

// Varicode lookup table
//
// This table defines the PKS31 varicode.  There are 128 entries,
// corresponding to ASCII characters 0-127 with two bytes for each entry.
// The bits for the varicode are to be shifted out LSB-first.
//
// More than one zero in sequence signifies the end of the character.
// For modulation, a 0 represents a phase reversal while a 1 
// represents a steady-state carrier.

uint16_t varicode[] = {
  0x0355,  // 0 NUL
  0x036d,  // 1 SOH
  0x02dd,  // 2 STX
  0x03bb,  // 3 ETX
  0x035d,  // 4 EOT
  0x03eb,  // 5 ENQ
  0x03dd,  // 6 ACK
  0x02fd,  // 7 BEL
  0x03fd,  // 8 BS
  0x00f7,  // 9 HT
  0x0017,  // 10 LF
  0x03db,  // 11 VT
  0x02ed,  // 12 FF
  0x001f,  // 13 CR
  0x02bb,  // 14 SO
  0x0357,  // 15 SI
  0x03bd,  // 16 DLE
  0x02bd,  // 17 DC1
  0x02d7,  // 18 DC2
  0x03d7,  // 19 DC3
  0x036b,  // 20 DC4
  0x035b,  // 21 NAK
  0x02db,  // 22 SYN
  0x03ab,  // 23 ETB
  0x037b,  // 24 CAN
  0x02fb,  // 25 EM
  0x03b7,  // 26 SUB
  0x02ab,  // 27 ESC
  0x02eb,  // 28 FS
  0x0377,  // 29 GS
  0x037d,  // 30 RS
  0x03fb,  // 31 US
  0x0001,  // 32 SP
  0x01ff,  // 33 !
  0x01f5,  // 34 @
  0x015f,  // 35 #
  0x01b7,  // 36 $
  0x02ad,  // 37 %
  0x0375,  // 38 &
  0x01fd,  // 39 '
  0x00df,  // 40 (
  0x00ef,  // 41 )
  0x01ed,  // 42 *
  0x01f7,  // 43 +
  0x0057,  // 44 ,
  0x002b,  // 45 -
  0x0075,  // 46 .
  0x01eb,  // 47 /
  0x00ed,  // 48 0
  0x00bd,  // 49 1
  0x00b7,  // 50 2
  0x00ff,  // 51 3
  0x01dd,  // 52 4
  0x01b5,  // 53 5
  0x01ad,  // 54 6
  0x016b,  // 55 7
  0x01ab,  // 56 8
  0x01db,  // 57 9
  0x00af,  // 58 :
  0x017b,  // 59 ;
  0x016f,  // 60 <
  0x0055,  // 61 =
  0x01d7,  // 62 >
  0x03d5,  // 63 ?
  0x02f5,  // 64 @
  0x005f,  // 65 A
  0x00d7,  // 66 B
  0x00b5,  // 67 C
  0x00ad,  // 68 D
  0x0077,  // 69 E
  0x00db,  // 70 F
  0x00bf,  // 71 G
  0x0155,  // 72 H
  0x007f,  // 73 I
  0x017f,  // 74 J
  0x017d,  // 75 K
  0x00eb,  // 76 L
  0x00dd,  // 77 M
  0x00bb,  // 78 N
  0x00d5,  // 79 O
  0x00ab,  // 80 P
  0x0177,  // 81 Q
  0x00f5,  // 82 R
  0x007b,  // 83 S
  0x005b,  // 84 T
  0x01d5,  // 85 U
  0x015b,  // 86 V
  0x0175,  // 87 W
  0x015d,  // 88 X
  0x01bd,  // 89 Y
  0x02d5,  // 90 Z
  0x01df,  // 91 [
  0x01ef,  // 92 
  0x01bf,  // 93 ]
  0x03f5,  // 94 ^
  0x016d,  // 95 _
  0x03ed,  // 96 `
  0x000d,  // 97 a
  0x007d,  // 98 b
  0x003d,  // 99 c
  0x002d,  // 100 d
  0x0003,  // 101 e
  0x002f,  // 102 f
  0x006d,  // 103 g
  0x0035,  // 104 h
  0x000b,  // 105 i
  0x01af,  // 106 j
  0x00fd,  // 107 k
  0x001b,  // 108 l
  0x0037,  // 109 m
  0x000f,  // 110 n
  0x0007,  // 111 o
  0x003f,  // 112 p
  0x01fb,  // 113 q
  0x0015,  // 114 r
  0x001d,  // 115 s
  0x0005,  // 116 t
  0x003b,  // 117 u
  0x006f,  // 118 v
  0x006b,  // 119 w
  0x00fb,  // 120 x
  0x005d,  // 121 y
  0x0157,  // 122 z
  0x03b5,  // 123 {
  0x01bb,  // 124 |
  0x02b5,  // 125 }
  0x03ad,  // 126 ~
  0x02b7   // 127 (del)
};

// 20 cycles of 25 samples each (500 bytes) of ramp-up
// sinusoid information.  There is an extra byte at the
// end of the table with the value 0x80 which allows the
// first byte to always be at the zero crossing point
// whether ramping up or down.
//
// Ramp profile is cosine shape.
char data[] =
{
  0x80,0x82,0x85,0x86,0x88,0x88,0x88,0x86,0x85,0x82,
  0x80,0x7E,0x7B,0x7A,0x78,0x78,0x78,0x7A,0x7B,0x7E,
  0x80,0x85,0x89,0x8D,0x8F,0x90,0x8F,0x8D,0x89,0x85,
  0x80,0x7B,0x77,0x73,0x71,0x70,0x71,0x73,0x77,0x7B,
  0x80,0x87,0x8E,0x93,0x97,0x98,0x97,0x93,0x8E,0x87,
  0x80,0x79,0x72,0x6D,0x69,0x68,0x69,0x6D,0x72,0x79,
  0x80,0x8A,0x92,0x99,0x9D,0x9F,0x9D,0x99,0x92,0x8A,
  0x80,0x76,0x6E,0x67,0x63,0x61,0x63,0x67,0x6E,0x76,
  0x80,0x8C,0x97,0xA0,0xA5,0xA7,0xA5,0xA0,0x97,0x8C,
  0x80,0x74,0x69,0x60,0x5B,0x59,0x5B,0x60,0x69,0x74,
  0x80,0x8F,0x9C,0xA6,0xAD,0xAF,0xAD,0xA6,0x9C,0x8F,
  0x80,0x71,0x64,0x5A,0x53,0x51,0x53,0x5A,0x64,0x71,
  0x80,0x91,0xA0,0xAC,0xB3,0xB6,0xB3,0xAC,0xA0,0x91,
  0x80,0x6F,0x60,0x54,0x4D,0x4A,0x4D,0x54,0x60,0x6F,
  0x80,0x93,0xA4,0xB1,0xBA,0xBD,0xBA,0xB1,0xA4,0x93,
  0x80,0x6D,0x5C,0x4F,0x46,0x43,0x46,0x4F,0x5C,0x6D,
  0x80,0x95,0xA8,0xB7,0xC1,0xC4,0xC1,0xB7,0xA8,0x95,
  0x80,0x6B,0x58,0x49,0x3F,0x3C,0x3F,0x49,0x58,0x6B,
  0x80,0x97,0xAC,0xBD,0xC7,0xCB,0xC7,0xBD,0xAC,0x97,
  0x80,0x69,0x54,0x43,0x39,0x35,0x39,0x43,0x54,0x69,
  0x80,0x99,0xB0,0xC2,0xCD,0xD1,0xCD,0xC2,0xB0,0x99,
  0x80,0x67,0x50,0x3E,0x33,0x2F,0x33,0x3E,0x50,0x67,
  0x80,0x9B,0xB3,0xC6,0xD3,0xD7,0xD3,0xC6,0xB3,0x9B,
  0x80,0x65,0x4D,0x3A,0x2D,0x29,0x2D,0x3A,0x4D,0x65,
  0x80,0x9D,0xB7,0xCB,0xD8,0xDD,0xD8,0xCB,0xB7,0x9D,
  0x80,0x63,0x49,0x35,0x28,0x23,0x28,0x35,0x49,0x63,
  0x80,0x9E,0xBA,0xCF,0xDD,0xE2,0xDD,0xCF,0xBA,0x9E,
  0x80,0x62,0x46,0x31,0x23,0x1E,0x23,0x31,0x46,0x62,
  0x80,0xA0,0xBD,0xD3,0xE2,0xE7,0xE2,0xD3,0xBD,0xA0,
  0x80,0x60,0x43,0x2D,0x1E,0x19,0x1E,0x2D,0x43,0x60,
  0x80,0xA1,0xBF,0xD7,0xE6,0xEB,0xE6,0xD7,0xBF,0xA1,
  0x80,0x5F,0x41,0x29,0x1A,0x15,0x1A,0x29,0x41,0x5F,
  0x80,0xA2,0xC1,0xDA,0xEA,0xEF,0xEA,0xDA,0xC1,0xA2,
  0x80,0x5E,0x3F,0x26,0x16,0x11,0x16,0x26,0x3F,0x5E,
  0x80,0xA4,0xC4,0xDD,0xED,0xF3,0xED,0xDD,0xC4,0xA4,
  0x80,0x5C,0x3C,0x23,0x13,0x0D,0x13,0x23,0x3C,0x5C,
  0x80,0xA4,0xC5,0xDF,0xF0,0xF6,0xF0,0xDF,0xC5,0xA4,
  0x80,0x5C,0x3B,0x21,0x10,0x0A,0x10,0x21,0x3B,0x5C,
  0x80,0xA5,0xC7,0xE2,0xF3,0xF9,0xF3,0xE2,0xC7,0xA5,
  0x80,0x5B,0x39,0x1E,0x0D,0x07,0x0D,0x1E,0x39,0x5B,
  0x80,0xA6,0xC8,0xE4,0xF5,0xFB,0xF5,0xE4,0xC8,0xA6,
  0x80,0x5A,0x38,0x1C,0x0B,0x05,0x0B,0x1C,0x38,0x5A,
  0x80,0xA7,0xC9,0xE5,0xF7,0xFD,0xF7,0xE5,0xC9,0xA7,
  0x80,0x59,0x37,0x1B,0x09,0x03,0x09,0x1B,0x37,0x59,
  0x80,0xA7,0xCA,0xE6,0xF8,0xFE,0xF8,0xE6,0xCA,0xA7,
  0x80,0x59,0x36,0x1A,0x08,0x02,0x08,0x1A,0x36,0x59,
  0x80,0xA7,0xCB,0xE7,0xF9,0xFF,0xF9,0xE7,0xCB,0xA7,
  0x80,0x59,0x35,0x19,0x07,0x01,0x07,0x19,0x35,0x59,
  0x80,0xA7,0xCB,0xE7,0xF9,0xFF,0xF9,0xE7,0xCB,0xA7,
  0x80,0x59,0x35,0x19,0x07,0x01,0x07,0x19,0x35,0x59,
  0x80
  };

// The last 20 bytes (21 with the extra on the end)
// define a single cycle of full amplitude sinusoid.
#define one  (&data[24*20])      // Sine table pointer for a one bit
#define zero (&data[25*20])      // Sine table pointer for a zero bit

// Variables used by the timer ISR to generate sinusoidal information.
volatile char    rgchBuf[256];    // Buffer of text to send
volatile uint8_t head = 0;        // Buffer head (next character to send)
volatile uint8_t tail = 0;        // Buffer tail (next insert point)

volatile uint16_t vcChar = 0;     // Current varicode char being sent

volatile int   cbHalfBit = 500;   // 500 phase points required for PSK 1/2 bit time

volatile char *pbSine = zero;
volatile int   cbDirection = 500;
volatile char  fSendOne = false;

volatile int ix       = -1;
volatile int phase    = 1;
volatile char fFullBit = 0;

volatile char cZeroBits = 0;
volatile char maxZeroBits = 2;

// Initialize the USB controller
USBHost usb;

// Attach keyboard controller to USB
KeyboardController keyboard(usb);

// True if the PSK engine is currently sending data
uint8_t fIsSending = false;

// Start the PSK engine transmitting if it is not already
void startTX()
{
  if (fIsSending) return;
    
  // Set timer to 31.25 kHz for a period of 32 us and start it
  TimerStart(TC1, 0, TC3_IRQn, 31250);
  fIsSending = true;
}

// Stop the PSK engine transmitting
void stopTX()
{
  TC_Stop(TC1, 0);
  fIsSending = false;
}
  
// Set up Timer/Counter (TC)
void TimerStart(Tc *tc, uint32_t channel, IRQn_Type irq, uint32_t freq)
{
   pmc_set_writeprotect(false);
   pmc_enable_periph_clk(irq);
   TC_Configure(tc, channel, TC_CMR_WAVE | TC_CMR_WAVSEL_UP_RC |
                             TC_CMR_TCCLKS_TIMER_CLOCK1);
   uint32_t rc = VARIANT_MCK / 2 / freq;
   TC_SetRC(tc, channel, rc);
   TC_Start(tc, channel);
   tc->TC_CHANNEL[channel].TC_IER=  TC_IER_CPCS; // | TC_IER_CPAS;
   tc->TC_CHANNEL[channel].TC_IDR=~(TC_IER_CPCS); // | TC_IER_CPAS);
   NVIC_EnableIRQ(irq);
}

// Timer 2 interrupt service routine (ISR).
//
// Grab the next phase point from the table and 
// set the amplitude value of the sinusoid being
// constructed.  For a one bit, set 500 phase points
// (20 amplitudes of 25 samples each) to ramp
// down to zero and then immediately back up to full
// amplitude for a total of 1024 phase points.
//
// For a zero bit, there is not amplitude or phase
// change, so we just play 20 phase points of
// full amplitude data 25 times for a total of 1000
// phase points.
//
// Each end of the ramp-up table starts with a zero 
// crossing byte, so there is one extra byte in
// the table (501 entries).  Ramping up plays bytes
// 0 -> 499 and ramping down plays bytes 500 -> 1
// allowing each direction to start at the zero
// crossing point.

//TC1 ch 0
void TC3_Handler()
{
   TC_GetStatus(TC1, 0);  // Reset TC
   
  // Set current amplitude value for the sine wave 
  // being constructed taking care to invert the
  // phase when processing the table in reverse order.
  analogWrite(DAC0, (*pbSine * ix * phase) & 0xff);
  pbSine += ix;
  
  // At the half bit time, we need to change phase
  // if generating a zero bit
  if (0 == --cbHalfBit)
  {
    cbHalfBit = 500;  // Reset 1/2 PSK bit time phase counter
    
    // Get the next varichar bit to send
    if (fFullBit)
    {
      // Count the number of sequential zero bits
      if (fSendOne = vcChar & 1) cZeroBits = 0; else cZeroBits++;

      // Shift off the most least significant bit.
      vcChar >>= 1;
      
      // If we have sent two zero bits, end of character has occurred
      if (cZeroBits > maxZeroBits)
      {
        cZeroBits = 0;
        
        // If send buffer not empty, get next varicode character
        if (head != tail)
        {
          // Assumes a 256 byte buffer as index increments modulo 256
          vcChar = varicode[rgchBuf[head++]];
        }
        else
          if (maxZeroBits > 2) stopTX(); else maxZeroBits = 4;
      }
    }
    fFullBit = !fFullBit;  // Toggle end of full bit flag
    
    // When we get done ramping down, phase needs to
    // change unless we are sending a one bit
    if (ix < 0 &&!fSendOne) phase = -phase;
  }
  
  // At the end of the table for the bit being
  // generated, we need to change direction
  // and process the table in the other direction.
  if (0 == --cbDirection)
  {
    cbDirection = fSendOne ? 20 : 500;
    ix = -ix;
  }
}

// Keyboard functionality follows
// Intercept key release
void keyReleased()
{
  char rgchTemp[] = {0, 0};
  const char *szText = &rgchTemp[0];
  int  cchText = 0;
  
  switch (keyboard.getOemKey())
  {
    case 58:  // F1
      szText = "\nCQ CQ CQ de ko7m ko7m ko7m"
               "\nCQ CQ CQ de ko7m ko7m ko7m"
               "\nCQ CQ CQ de ko7m ko7m ko7m CN87xp pse k\n";
      break;
      
    case 59:  // F2
      szText = "\n Me: Jeff - ko7m"
               "\nLoc: Redmond, Washington USA"
               "\nGrd: CN87xp"
               "\nQSL: eQSL, direct or bureau"
               "\nRig: Homebrew SSB transceiver"
               "\nAnt: G5RV at about 8 metres"
               "\nPSK: Homebrew Arduino Due software"
               "\n";
      break;

    case 60:  // F3
      szText = "\n\nSo, back to you!\n";
      break;
      
    case 61:  // F4
      szText = "\nTnx for the nice QSO"
               "\nBest of 73's to you and yours!"
               "\n";
      break;
      
    case 62:  // F5
      szText = " de jeff -ko7m\n\n";
      break;
    
    case 40:  // CR
      szText = "\r\n";
      break;
      
    default:
      rgchTemp[0] = keyboard.getKey();
      rgchTemp[1] = 0;
      break;
  }
  
  cchText = strlen(szText);
  while (cchText--)
    rgchBuf[tail++] = *szText++;

  startTX();  // Start the PSK engine if it is stopped
}

// Set up our pins, analogue conversion, buffers and timers 
void setup()
{
  // Use 8 bits in analogue conversions
  analogWriteResolution(8);
  analogReadResolution(8);

  tail = head = 0;
 }

// Process USB tasks in main loop
void loop() 
{
  usb.Task();
}

Monday, March 2, 2015

Generating Audio PSK31 with an Arduino (Part 3) UPDATE

UPDATED: Complete code listing added to end of posting.  Apologies for previously posting an incorrect (and non-functional) version of the code.  The corrected code is now included at the end of this posting.

In three previous posts (part 1, update, part 2), I have described a working PSK31 encoder implemented on an Arduino ATMega328 or ATMega2560 device.  While this implementation worked for the most part, it was based on some incorrect PSK32 bit timing.  Most PSK31 decoders are sufficiently robust to allow successful decoding of my generated signal, but I wanted to write a follow-up posting to describe the error and propose a fix.

By way of review, PSK31 is a communication protocol with a transmission rate of 31.25 baud.  So, what does this mean?  From google, we see the following definition of "baud".


So, a 31.25 baud transmission is 31.25 bits per second or a bit time of 32 ms.  The technique described in my previous postings (above) results in a bit time of 32.768 ms which apparently is still decode-able, but I would still like to get this right.

My error is in how I constructed the waveform of the PSK31 signal.  I used a 1 kHz tone which of course has a 1 ms period (1/1000 = .001 seconds).  To construct this 1 kHz tone, I generated 32 phase points per cycle.  This means that I needed to generate a new phase point every 31.25 us.  (.001 / 32 = .00003125 seconds = 31.25 us).  To do this, I used a timer driven at 16 MHz in phase correct PWM mode.  This means that the timer counts from zero to 255 and then back down to zero at which time it generates an interrupt.  Therefore, the interrupt would happen every 512 ticks of the 16 MHz clock which is every 32 us.  (16000000 / 512 = 31250 = .000032 seconds = 32 us)

So, instead of generating a phase point every 31.25 us, I was generating one every 32 us. (Hey, what's 0.75 us amongst friends?)  This in and of itself is not really a problem, but the error I made was that I was using a model where I generated 1024 phase points per PSK31 bit time.  Therefore, my bit time ended up being 32.768 ms rather than the desired 32 ms.  (1024 * .000032 = .032768 seconds = 32.768 ms).

In an ideal world, I would run the timer at 16 MHz / 500 = 32 kHz instead of 16 MHz / 512 = 31.25 kHz and my current scheme would work fine.  The counter would run from zero to 250 and then back down to zero instead of counting up to 255.  However, there are a limited number of prescaler divisors available on Arduino timers and they are all powers of two, so this is not an option.  Additionally, I need phase correct PWM mode, so the counter has to run from minimum (zero) to max (255) and back down for each phase point.  The 1 kHz tone output goes high at the current phase amplitude value when the counter gets to it on the way up to 255 and sets the output low when the counter gets to the phase amplitude value on the way back down to zero.  This allows the generation of phase correct PWM output.  Once the PWM output is integrated, a nice phase continuous sine wave output is produced.

So, the fix appears to be to use 1000 phase points per PSK31 bit time rather than 1024.  (1000 * .000032 = .032 = 32 ms)  I will need to re-generate the sine tables to use possibly 20 phase points per cycle rather than 32 and make sure the state machine knows the new number of phase points per cycle, so the code changes should be pretty trivial (famous last words...)

The implementation does not separate the bit timing from the timing of the generation of the 1 kHz audio tone.  We count cycles to know when the bit has ended.  If these timing tasks were separated, then we could set the bit time independently of the frequency of the tone being generated.  But, since I coupled these two things together, I have to change the number of phase points per cycle in order to generate the correct character timing.

Here is the updated code listing with the changes discussed above.  I have verified the bit timing is now correct.

As always, your mileage may vary.  I am happy to try and help you if you have questions or comments about anything you read here.  Post a reply here or drop me a note at ko7m at arrl dot net.

// PSK31 audio generation
// Jeff Whitlatch - ko7m

// We are going to generate a 1 kHz centre frequency tone.  
// Each 1 kHz cycle of the sinusoid will be generated from
// 32 eight bit amplitude samples.  The period of a 1 kHz tone
// is 1 ms.  Each of the 32 samples per cycle has a period
// of 31.25 us.  We will construct each sinusoid from a 32 byte
// per cycle lookup table of amplitude values ranging from
// 0x00 to 0xff where the zero crossing value is 0x80.

// The PSK31 character bit time is 31.25 ms constructed of 1024
// samples.  A binary zero is represented by a phase reversal
// while a binary 1 is represented by the lack of a phase reversal.

// Characters are encoded with a variable bit length code (varicode)
// where the length of each character is inversely
// proportional to the frequency of use in the english language 
// of that character.  Characters are encoded with a bit
// pattern where there are no sequential zero bits.  Two zero bits
// in a row signify the end of a character.

// Varicode lookup table
//
// This table defines the PKS31 varicode.  There are 128 entries,
// corresponding to ASCII characters 0-127 with two bytes for each entry.
// The bits for the varicode are to be shifted out LSB-first.
//
// More than one zero in sequence signifies the end of the character.
// For modulation, a 0 represents a phase reversal while a 1 
// represents a steady-state carrier.

uint16_t varicode[] = {
  0x0355,  // 0 NUL
  0x036d,  // 1 SOH
  0x02dd,  // 2 STX
  0x03bb,  // 3 ETX
  0x035d,  // 4 EOT
  0x03eb,  // 5 ENQ
  0x03dd,  // 6 ACK
  0x02fd,  // 7 BEL
  0x03fd,  // 8 BS
  0x00f7,  // 9 HT
  0x0017,  // 10 LF
  0x03db,  // 11 VT
  0x02ed,  // 12 FF
  0x001f,  // 13 CR
  0x02bb,  // 14 SO
  0x0357,  // 15 SI
  0x03bd,  // 16 DLE
  0x02bd,  // 17 DC1
  0x02d7,  // 18 DC2
  0x03d7,  // 19 DC3
  0x036b,  // 20 DC4
  0x035b,  // 21 NAK
  0x02db,  // 22 SYN
  0x03ab,  // 23 ETB
  0x037b,  // 24 CAN
  0x02fb,  // 25 EM
  0x03b7,  // 26 SUB
  0x02ab,  // 27 ESC
  0x02eb,  // 28 FS
  0x0377,  // 29 GS
  0x037d,  // 30 RS
  0x03fb,  // 31 US
  0x0001,  // 32 SP
  0x01ff,  // 33 !
  0x01f5,  // 34 @
  0x015f,  // 35 #
  0x01b7,  // 36 $
  0x02ad,  // 37 %
  0x0375,  // 38 &
  0x01fd,  // 39 '
  0x00df,  // 40 (
  0x00ef,  // 41 )
  0x01ed,  // 42 *
  0x01f7,  // 43 +
  0x0057,  // 44 ,
  0x002b,  // 45 -
  0x0075,  // 46 .
  0x01eb,  // 47 /
  0x00ed,  // 48 0
  0x00bd,  // 49 1
  0x00b7,  // 50 2
  0x00ff,  // 51 3
  0x01dd,  // 52 4
  0x01b5,  // 53 5
  0x01ad,  // 54 6
  0x016b,  // 55 7
  0x01ab,  // 56 8
  0x01db,  // 57 9
  0x00af,  // 58 :
  0x017b,  // 59 ;
  0x016f,  // 60 <
  0x0055,  // 61 =
  0x01d7,  // 62 >
  0x03d5,  // 63 ?
  0x02f5,  // 64 @
  0x005f,  // 65 A
  0x00d7,  // 66 B
  0x00b5,  // 67 C
  0x00ad,  // 68 D
  0x0077,  // 69 E
  0x00db,  // 70 F
  0x00bf,  // 71 G
  0x0155,  // 72 H
  0x007f,  // 73 I
  0x017f,  // 74 J
  0x017d,  // 75 K
  0x00eb,  // 76 L
  0x00dd,  // 77 M
  0x00bb,  // 78 N
  0x00d5,  // 79 O
  0x00ab,  // 80 P
  0x0177,  // 81 Q
  0x00f5,  // 82 R
  0x007b,  // 83 S
  0x005b,  // 84 T
  0x01d5,  // 85 U
  0x015b,  // 86 V
  0x0175,  // 87 W
  0x015d,  // 88 X
  0x01bd,  // 89 Y
  0x02d5,  // 90 Z
  0x01df,  // 91 [
  0x01ef,  // 92 
  0x01bf,  // 93 ]
  0x03f5,  // 94 ^
  0x016d,  // 95 _
  0x03ed,  // 96 `
  0x000d,  // 97 a
  0x007d,  // 98 b
  0x003d,  // 99 c
  0x002d,  // 100 d
  0x0003,  // 101 e
  0x002f,  // 102 f
  0x006d,  // 103 g
  0x0035,  // 104 h
  0x000b,  // 105 i
  0x01af,  // 106 j
  0x00fd,  // 107 k
  0x001b,  // 108 l
  0x0037,  // 109 m
  0x000f,  // 110 n
  0x0007,  // 111 o
  0x003f,  // 112 p
  0x01fb,  // 113 q
  0x0015,  // 114 r
  0x001d,  // 115 s
  0x0005,  // 116 t
  0x003b,  // 117 u
  0x006f,  // 118 v
  0x006b,  // 119 w
  0x00fb,  // 120 x
  0x005d,  // 121 y
  0x0157,  // 122 z
  0x03b5,  // 123 {
  0x01bb,  // 124 |
  0x02b5,  // 125 }
  0x03ad,  // 126 ~
  0x02b7   // 127 (del)
};

// 25 cycles of 20 samples each (500 bytes) of ramp-up
// sinusoid information.  There is an extra byte at the
// end of the table with the value 0x80 which allows the
// first byte to always be at the zero crossing point
// whether ramping up or down.
//
char data[] =
{
  0x80,0x82,0x85,0x86,0x88,0x88,0x88,0x86,0x85,0x82,
  0x80,0x7E,0x7B,0x7A,0x78,0x78,0x78,0x7A,0x7B,0x7E,
  0x80,0x85,0x89,0x8D,0x8F,0x90,0x8F,0x8D,0x89,0x85,
  0x80,0x7B,0x77,0x73,0x71,0x70,0x71,0x73,0x77,0x7B,
  0x80,0x87,0x8E,0x93,0x97,0x98,0x97,0x93,0x8E,0x87,
  0x80,0x79,0x72,0x6D,0x69,0x68,0x69,0x6D,0x72,0x79,
  0x80,0x8A,0x92,0x99,0x9D,0x9F,0x9D,0x99,0x92,0x8A,
  0x80,0x76,0x6E,0x67,0x63,0x61,0x63,0x67,0x6E,0x76,
  0x80,0x8C,0x97,0xA0,0xA5,0xA7,0xA5,0xA0,0x97,0x8C,
  0x80,0x74,0x69,0x60,0x5B,0x59,0x5B,0x60,0x69,0x74,
  0x80,0x8F,0x9C,0xA6,0xAD,0xAF,0xAD,0xA6,0x9C,0x8F,
  0x80,0x71,0x64,0x5A,0x53,0x51,0x53,0x5A,0x64,0x71,
  0x80,0x91,0xA0,0xAC,0xB3,0xB6,0xB3,0xAC,0xA0,0x91,
  0x80,0x6F,0x60,0x54,0x4D,0x4A,0x4D,0x54,0x60,0x6F,
  0x80,0x93,0xA4,0xB1,0xBA,0xBD,0xBA,0xB1,0xA4,0x93,
  0x80,0x6D,0x5C,0x4F,0x46,0x43,0x46,0x4F,0x5C,0x6D,
  0x80,0x95,0xA8,0xB7,0xC1,0xC4,0xC1,0xB7,0xA8,0x95,
  0x80,0x6B,0x58,0x49,0x3F,0x3C,0x3F,0x49,0x58,0x6B,
  0x80,0x97,0xAC,0xBD,0xC7,0xCB,0xC7,0xBD,0xAC,0x97,
  0x80,0x69,0x54,0x43,0x39,0x35,0x39,0x43,0x54,0x69,
  0x80,0x99,0xB0,0xC2,0xCD,0xD1,0xCD,0xC2,0xB0,0x99,
  0x80,0x67,0x50,0x3E,0x33,0x2F,0x33,0x3E,0x50,0x67,
  0x80,0x9B,0xB3,0xC6,0xD3,0xD7,0xD3,0xC6,0xB3,0x9B,
  0x80,0x65,0x4D,0x3A,0x2D,0x29,0x2D,0x3A,0x4D,0x65,
  0x80,0x9D,0xB7,0xCB,0xD8,0xDD,0xD8,0xCB,0xB7,0x9D,
  0x80,0x63,0x49,0x35,0x28,0x23,0x28,0x35,0x49,0x63,
  0x80,0x9E,0xBA,0xCF,0xDD,0xE2,0xDD,0xCF,0xBA,0x9E,
  0x80,0x62,0x46,0x31,0x23,0x1E,0x23,0x31,0x46,0x62,
  0x80,0xA0,0xBD,0xD3,0xE2,0xE7,0xE2,0xD3,0xBD,0xA0,
  0x80,0x60,0x43,0x2D,0x1E,0x19,0x1E,0x2D,0x43,0x60,
  0x80,0xA1,0xBF,0xD7,0xE6,0xEB,0xE6,0xD7,0xBF,0xA1,
  0x80,0x5F,0x41,0x29,0x1A,0x15,0x1A,0x29,0x41,0x5F,
  0x80,0xA2,0xC1,0xDA,0xEA,0xEF,0xEA,0xDA,0xC1,0xA2,
  0x80,0x5E,0x3F,0x26,0x16,0x11,0x16,0x26,0x3F,0x5E,
  0x80,0xA4,0xC4,0xDD,0xED,0xF3,0xED,0xDD,0xC4,0xA4,
  0x80,0x5C,0x3C,0x23,0x13,0x0D,0x13,0x23,0x3C,0x5C,
  0x80,0xA4,0xC5,0xDF,0xF0,0xF6,0xF0,0xDF,0xC5,0xA4,
  0x80,0x5C,0x3B,0x21,0x10,0x0A,0x10,0x21,0x3B,0x5C,
  0x80,0xA5,0xC7,0xE2,0xF3,0xF9,0xF3,0xE2,0xC7,0xA5,
  0x80,0x5B,0x39,0x1E,0x0D,0x07,0x0D,0x1E,0x39,0x5B,
  0x80,0xA6,0xC8,0xE4,0xF5,0xFB,0xF5,0xE4,0xC8,0xA6,
  0x80,0x5A,0x38,0x1C,0x0B,0x05,0x0B,0x1C,0x38,0x5A,
  0x80,0xA7,0xC9,0xE5,0xF7,0xFD,0xF7,0xE5,0xC9,0xA7,
  0x80,0x59,0x37,0x1B,0x09,0x03,0x09,0x1B,0x37,0x59,
  0x80,0xA7,0xCA,0xE6,0xF8,0xFE,0xF8,0xE6,0xCA,0xA7,
  0x80,0x59,0x36,0x1A,0x08,0x02,0x08,0x1A,0x36,0x59,
  0x80,0xA7,0xCB,0xE7,0xF9,0xFF,0xF9,0xE7,0xCB,0xA7,
  0x80,0x59,0x35,0x19,0x07,0x01,0x07,0x19,0x35,0x59,
  0x80,0xA7,0xCB,0xE7,0xF9,0xFF,0xF9,0xE7,0xCB,0xA7,
  0x80,0x59,0x35,0x19,0x07,0x01,0x07,0x19,0x35,0x59,
  0x80
  };

// The last 20 bytes (21 with the extra on the end)
// define a single cycle of full amplitude sinusoid.
#define one  (&data[24*20])      // Sine table pointer for a one bit
#define zero (&data[25*20])      // Sine table pointer for a zero bit

// Useful macros for setting and resetting bits
#define cbi(sfr, bit) (_SFR_BYTE(sfr) &= ~_BV(bit))
#define sbi(sfr, bit) (_SFR_BYTE(sfr) |= _BV(bit))

// Variables used by the timer ISR to generate sinusoidal information.
volatile char    rgchBuf[256];    // Buffer of text to send
volatile uint8_t head = 0;        // Buffer head (next character to send)
volatile uint8_t tail = 0;        // Buffer tail (next insert point)

volatile uint16_t vcChar = 0;     // Current varicode char being sent

volatile int   cbHalfBit = 500;   // 500 phase points required for PSK 1/2 bit time

volatile char *pbSine = zero;
volatile int   cbDirection = 500;
volatile char  fSendOne = false;

//volatile char *pbSine = one;
//volatile int   cbDirection = 32;
//volatile char  fSendOne = true;

volatile char ix       = -1;
volatile char phase    = 1;
volatile char fFullBit = 0;

volatile char cZeroBits = 0;
volatile char maxZeroBits = 2;

// Setup timer2 with prescaler = 1, PWM mode to phase correct PWM
// See the ATMega datasheet for all the gory details

void timer2Setup()
{
  // Clock prescaler = 1
  sbi (TCCR2B, CS20);    // 001 = no prescaling
  cbi (TCCR2B, CS21);
  cbi (TCCR2B, CS22);

  // Phase Correct PWM
  cbi (TCCR2A, COM2A0);  // 10 = clear OC2A on compare match when up counting
  sbi (TCCR2A, COM2A1);  //      set OC2A on compare match when down counting

  // Mode 1
  sbi (TCCR2A, WGM20);   // 01 = Mode 1 uses 0xff as TOP value
  cbi (TCCR2A, WGM21);
}

// Timer 2 interrupt service routine (ISR).
//
// Grab the next phase point from the table and 
// set the amplitude value of the sinusoid being
// constructed.  For a one bit, set 500 phase points
// (20 amplitudes of 25 samples each) to ramp
// down to zero and then immediately back up to full
// amplitude for a total of 1024 phase points.
//
// For a zero bit, there is not amplitude or phase
// change, so we just play 32 phase points of
// full amplitude data 32 times for a total of 1024
// phase points.
//
// Each end of the ramp-up table starts with a zero 
// crossing byte, so there is one extra byte in
// the table (501 entries).  Ramping up plays bytes
// 0 -> 499 and ramping down plays bytes 500 -> 1
// allowing each direction to start at the zero
// crossing point.
ISR(TIMER2_OVF_vect)
{
  // Set current amplitude value for the sine wave 
  // being constructed taking care to invert the
  // phase when processing the table in reverse order.
  OCR2A = *pbSine * ix * phase;
  pbSine += ix;
  
  // At the half bit time, we need to change phase
  // if generating a zero bit
  if (0 == --cbHalfBit)
  {
    cbHalfBit = 500;  // Reset 1/2 PSK bit time phase counter
    
    // Get the next varichar bit to send
    if (fFullBit)
    {
      // Count the number of sequential zero bits
      if (fSendOne = vcChar & 1) cZeroBits = 0; else cZeroBits++;

      // Shift off the most least significant bit.
      vcChar >>= 1;
      
      // If we have sent two zero bits, end of character has occurred
      if (cZeroBits > maxZeroBits)
      {
        cZeroBits = 0;
        
        // If send buffer not empty, get next varicode character
        if (head != tail)
        {
          // Assumes a 256 byte buffer as index increments modulo 256
          vcChar = varicode[rgchBuf[head++]];
        }
        else
          if (maxZeroBits > 2) cbi (TIMSK2,TOIE2); else maxZeroBits = 75;
      }
    }
    
    fFullBit = !fFullBit;  // Toggle end of full bit flag
    
    // When we get done ramping down, phase needs to
    // change unless we are sending a one bit
    if (ix < 0 &&!fSendOne) phase = -phase;
  }
  
  // At the end of the table for the bit being
  // generated, we need to change direction
  // and process the table in the other direction.
  if (0 == --cbDirection)
  {
    cbDirection = fSendOne ? 20 : 500;
    ix = -ix;
  }
}

void setup() 
{
  // PWM output for timer2 is pin 10 on the ATMega2560
  // If you use an ATMega328 (such as the UNO) you need
  // to make this pin 11
  // See https://spreadsheets.google.com/pub?key=rtHw_R6eVL140KS9_G8GPkA&gid=0
  pinMode(10, OUTPUT);   // Timer 2 PWM output on mega256 is pin 10

  // Set up timer2 to a phase correct 32kHz clock
  timer2Setup();

  // Put something in the buffer to be sent
  strcpy((char *) &rgchBuf[0], "\nCQ CQ CQ de ko7m ko7m ko7m"
                               "\nCQ CQ CQ de ko7m ko7m ko7m"
                               "\nCQ CQ CQ de ko7m ko7m ko7m CN87xp pse k\n");
  tail = strlen((const char *) rgchBuf);
  head = 0;
  
  sbi (TIMSK2,TOIE2);    // Enable timer 2.
}

void loop() 
{
}

Sunday, February 15, 2015

Sorry to be absent for a while

I had hoped to be more active posting of late but I guess it has been my turn to deal with pesky medical issues since about Christmas.  After this week, I think things will normalize a little more for me and I will get back to more regular postings.

73's de Jeff - ko7m

Monday, February 2, 2015

Arduino Due High Frequency Waveform Output

In response to a previous post on Due Timers a reader asked if it was possible to obtain more than 1 MHz output frequency for a generated waveform.  To examine this question, I initially looked at performance using the simplest approach to generating a waveform output by bit banging the output waveform.

void setup() 
{
  pinMode(8, OUTPUT);
}
void loop() 
{  
  while (true) 
  {
    digitalWrite(8, HIGH);
    digitalWrite(8, LOW);
  }
}

This bit of code will allow the generation of a 200 kHz square wave on digital pin 8.  The while loop in the loop function may not be obvious as to it's function.  If we comment out this while statement line, our output frequency changes from 200 kHz to approximately 144.5 kHz and the waveform is no longer symmetrical 50% duty cycle.  This is caused by the routine that calls the loop function doing some checking of the serial port on each iteration.  So, to eliminate this overhead, I use my own while loop.

The next most obvious way to improve on this performance is to eliminate the overhead of the digitalWrite call and manipulate the port directly.

void setup() 
{
  pinMode(8, OUTPUT);
}
void loop() 
{  
  while (true) 
  {
    g_APinDescription[8].pPort -> PIO_SODR = g_APinDescription[8].ulPin;
    g_APinDescription[8].pPort -> PIO_CODR = g_APinDescription[8].ulPin;
  }
}

With this code I can now obtain approximately 16.9 MHz square wave output on pin 8.  The waveform has a bit of overshoot at this frequency.  This approach also suffers from the inability to accurately control the frequency.

When looking to see just how fast we can clock the PWM outputs, as noted in my previous post you will find that the highest PWM clock frequency that can be accomodated is 42 MHz.  If you look at pmc.c and pwmc.c in hardware/archino/sam/system/libsam/source you will notice that a function "FindClockConfiguration" is used to ensure that the frequency parameter passed is less than the master clock (MCK) frequency of 84 MHz.  With integer dividers used as a prescaler, the smallest prescale value of 2 results in a 42 MHz frequency.

So, if you are looking for  a way to output the highest frequency possible, use a one bit PWM which will essentially output a square wave with a duty cycle of one.  Setting the prescaler to 2 will obtain an 84 MHz waveform.

uint32_t pwmPin = 8;
uint32_t maxDutyCount = 2;
uint32_t clkAFreq = 42000000ul;
uint32_t pwmFreq = 42000000ul; 
void setup() {
  pmc_enable_periph_clk(PWM_INTERFACE_ID);
  PWMC_ConfigureClocks(clkAFreq, 0, VARIANT_MCK);
  PIO_Configure(
    g_APinDescription[pwmPin].pPort,
    g_APinDescription[pwmPin].ulPinType,
    g_APinDescription[pwmPin].ulPin,
    g_APinDescription[pwmPin].ulPinConfiguration);
  uint32_t channel = g_APinDescription[pwmPin].ulPWMChannel;
  PWMC_ConfigureChannel(PWM_INTERFACE, channel , pwmFreq, 0, 0);
  PWMC_SetPeriod(PWM_INTERFACE, channel, maxDutyCount);
  PWMC_EnableChannel(PWM_INTERFACE, channel);
  PWMC_SetDutyCycle(PWM_INTERFACE, channel, 1);
  pmc_mck_set_prescaler(2);
}
void loop() 
{
}

Many thanks to Kerry Wong for providing most of the details above.